Towards Low-Latency Object Detection on Board Reactive Search-and-Rescue Drones
Sep 9, 2025·
 ,
,
,
,
 ,
,
,
,
,
,
,
·
0 min read
Ismail Amessegher
Arthur Gaudard
Kojo Nyamekye Anyinam-Boateng
Hugo Le Blévec
Lionel Génevé
Florian Pouthier
Mathieu Leonardon
Hajer Fradi
Lucia Bergantin
Panagiotis Papadakis
Isabelle Fantoni
Jean-Philippe Diguet
Matthieu Arzel
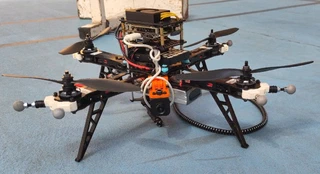 Image credit: Matthieu Arzel
Abstract
Drones play a crucial role in search and rescue missions by providing real-time information on areas of interest that are difficult to access or endangering to human rescuers. However, analyzing raw video feeds by human operators to detect objects of interest, such as vehicles or victims, becomes increasingly demanding as the mission duration increases. This underscores the need for embedded computer vision to reduce the operator’s cognitive load and enhance mission responsiveness. Towards this goal, we propose a low-latency object detection model based on YOLO, fitted to SAR missions, and able to process data coming from RGB and event cameras. We also propose a low-latency implementation on FPGA on board drones, achieving accurate detection in less than 10ms. Through a series of tests performed indoors using a prototype drone, we highlight the features of the model and processing core that favor drone reactivity and operational autonomy.
Type
Publication
2025 IEEE International Conference on Safety, Security, and Rescue Robotics
Status
Peer-reviewed
Open access
License
CC-BY-4.0

Authors
Doctor in Control and Robotics
My research focuses on the efficient navigation of UAVs in constrained environments. I recently joined the LEASARD CominLabs project at LS2N Nantes, in which I investigate SLAM and navigation algorithms with event-based cameras to improve drone autonomy in cluttered environments. This work is supervised by Isabelle Fantoni. My Ph.D. thesis work, led at ICube Strasbourg and GIPSA-lab Grenoble, has been dedicated to the event-driven navigation of a drone in dark environments, as a part of the dark-NAV ANR project. This thesis has been supervised by Nicolas Marchand and Sylvain Durand. Through my research work, I developed research interests in aerial robotics, robust control and set theory. As a graduate of an engineering school (INSA Strasbourg), I have developed a taste for control theory, which I try to deploy as much as possible on real control systems.