Innovative and Frugal Design of a Modular and Reconfigurable System of UAVs
Aug 27, 2025·
,
,
 ,
 ·
0 min read
Sylvain Boëgeat
Augustin Bonnel
Leandro Peixoto Mattos
Florian Pouthier
Hicham Chibane
Sylvain Durand
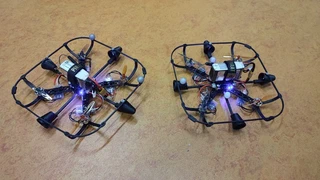 Image credit: Sylvain Boëgeat
Abstract
The growing demand for agile and adaptive aerial systems has led to significant advances in model-building technologies, with increasing interest in modular and reconfigurable Unmanned Aerial Vehicles (UAVs). This project investigates the prototyping of a system of UAVs (here of the quadcopter type) capable of assembling and disassembling in mid-flight to form larger structures or navigate in narrow environments. In contrast to existing approaches that slightly adapt a structure to make the UAV modular, we propose an innovative and frugal design of the frame from scratch that integrates, in particular, original (cone-shaped) attachment devices which can allow certain degrees of freedom with neighbors, propeller protections for safety with the surrounding environment, and other design tricks. The study presents a comprehensive approach encompassing mechanical design, 3D prototyping, and first-flight control to meet the challenges associated with modular and reconfigurable aerial systems.
Type
Publication
26th French Congress of Mechanics
Status
Peer-reviewed
Open access
License
CC-BY-4.0

Authors
Doctor in Control and Robotics
My research focuses on the efficient navigation of UAVs in constrained environments. I recently joined the LEASARD CominLabs project at LS2N Nantes, in which I investigate SLAM and navigation algorithms with event-based cameras to improve drone autonomy in cluttered environments. This work is supervised by Isabelle Fantoni. My Ph.D. thesis work, led at ICube Strasbourg and GIPSA-lab Grenoble, has been dedicated to the event-driven navigation of a drone in dark environments, as a part of the dark-NAV ANR project. This thesis has been supervised by Nicolas Marchand and Sylvain Durand. Through my research work, I developed research interests in aerial robotics, robust control and set theory. As a graduate of an engineering school (INSA Strasbourg), I have developed a taste for control theory, which I try to deploy as much as possible on real control systems.