Synchronization of a New Light-Flashing Shield With an External-Triggered Camera
Aug 1, 2023·
,
,
,
 ,

 ,
·
0 min read
José de Jesus Castillo-Zamora
Amaury Negre
Jean-Marc Ingargiola
Abdoullah Ndoye
Florian Pouthier
Jonathan Dumon
Sylvain Durand
Nicolas Marchand
Franck Ruffier
Abstract
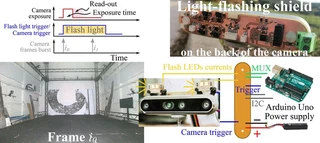
In this letter, we describe a new light-flashing shield to be used at flash-based imaging or event-based vision tasks performed in environments with poor light conditions. The shield incorporates a multiplexer that permits to set the operation mode, the nominal current, the pulse-width and the trigger sensitivity of up-to 2 high-brightness LEDs by means of a single I2C bus. A trigger conditioning circuit permits to synchronize the LEDs light and an Intel RealSense d455 camera to obtain a set of clear images while the LEDs are illuminated, being this feature the main novelty and contribution of this work in order to provide light on-demand in visual-based tasks performed in environments with poor light conditions. Images obtained during real tests prove the correct synchronization between the light-flashing shield and the camera.
Type
Publication
IEEE Sensors Letters, 7(8)
Status
Peer-reviewed
Open access
Funding
ANR Dark-NAV (ANR-20-CE33-0009)
ANR ROBOTEX 2.0 (ANR-10-EQPX-44-01)
License
CC-BY-4.0

Authors
Doctor in Control and Robotics
My research focuses on the efficient navigation of UAVs in constrained environments. I recently joined the LEASARD CominLabs project at LS2N Nantes, in which I investigate SLAM and navigation algorithms with event-based cameras to improve drone autonomy in cluttered environments. This work is supervised by Isabelle Fantoni. My Ph.D. thesis work, led at ICube Strasbourg and GIPSA-lab Grenoble, has been dedicated to the event-driven navigation of a drone in dark environments, as a part of the dark-NAV ANR project. This thesis has been supervised by Nicolas Marchand and Sylvain Durand. Through my research work, I developed research interests in aerial robotics, robust control and set theory. As a graduate of an engineering school (INSA Strasbourg), I have developed a taste for control theory, which I try to deploy as much as possible on real control systems.
